ESEN

Leví Gadiel Sojos González

Summer professional internship 2026-27. Seeking an internship or junior role in process control and automation.

Final-year Electronic Civil Engineering student at Universidad de Concepción (DIE UdeC). Bachelor of Engineering Sciences. Minor in Process Automation, Advanced Control and Industrial Robotics.

Email: levsojos2021@udec.cl
GitHub: github.com/gadivalr
LinkedIn: linkedin.com/in/levsojos
Language: English level B1

01. Projects

01
Electronics Project · 2026-2

Commissioning and start-up of the AspenTech DMC3 Calibrate module

Problem

A predictive controller loses performance when the plant drifts from the model it was identified with. Calibrate proposes re-identifying that model while the controller operates, but for that it needs to be connected to the plant with historical data being recorded. The question was whether it could recover a correct model after a plant change.

What I did
  • I built a simulated blending plant in Simulink and connected it to DMC3 via OPC UA.
  • I set up the real-time data historization and kept it running.
  • I introduced an intentional gain change in the plant and tested whether Calibrate detected and corrected it.
Result: Calibrate re-identified the gain as 0.7221 versus a true value of 0.72 (0.29% error).
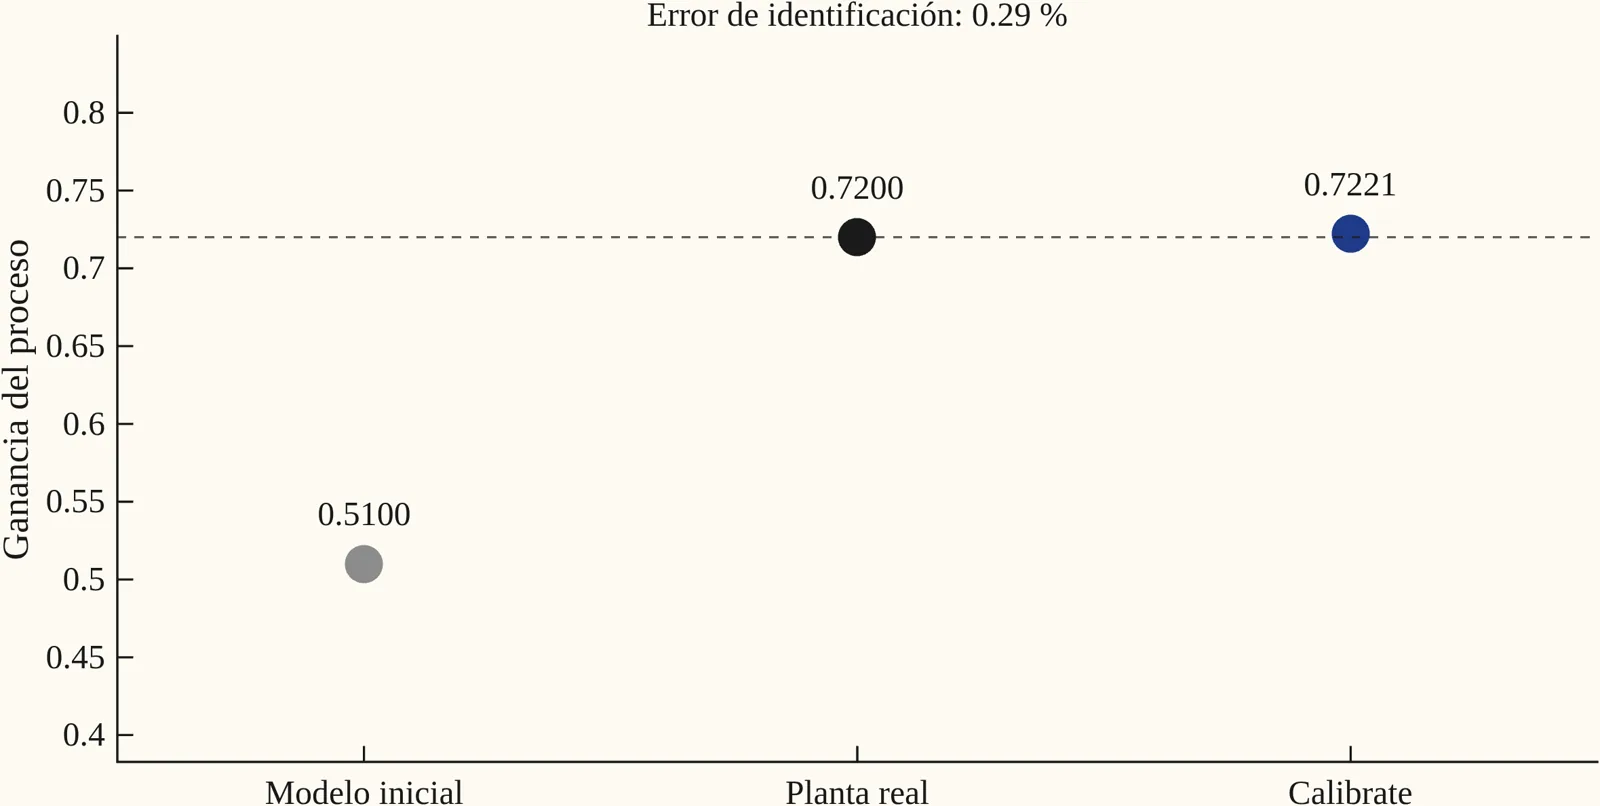
Gain re-identification plot from the Calibrate (DMC3) module after an intentional plant change.

Fig. 1.1 — Gain re-identification plot with Calibrate (DMC3) after an intentional plant change: estimated gain 0.7221 versus a true value of 0.72 (0.29% error).
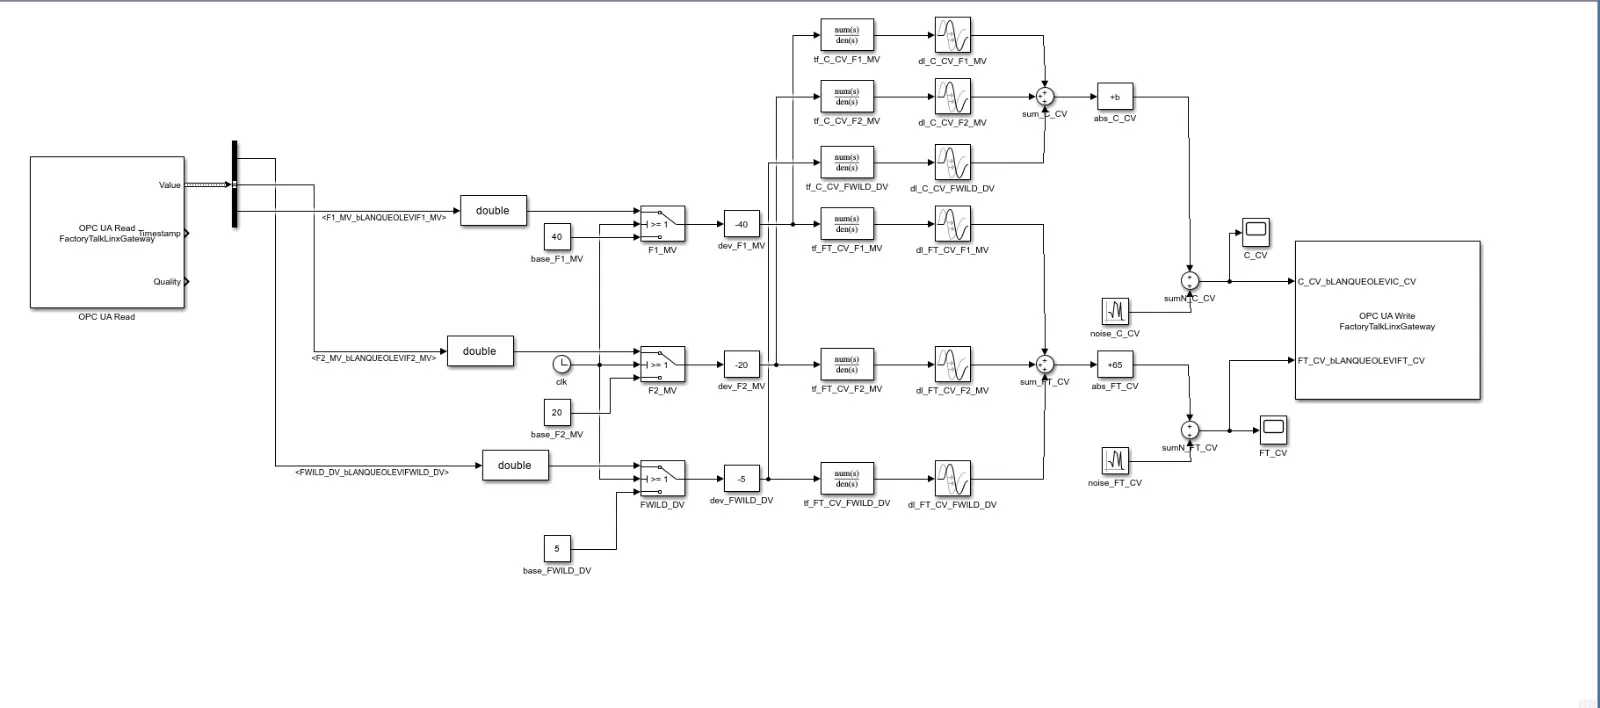
Simulink model of the simulated blending plant.

Fig. 1.2 — Simulated blending plant in Simulink, connected to DMC3 via OPC UA.
02
Format: Team project · Industrial Control

Control of a pilot plant with 4 coupled tanks

Problem

In a four-coupled-tank plant, each pump affects more than one level, so controlling each level separately is difficult and a disturbance in one tank propagates to the others. Testing controllers directly on the real plant is slow and risky.

What I did
  • I trained an ANFIS model of the plant to design and test the control in simulation first, before moving to the real plant.
  • Programmed the fuzzy (Sugeno) controller with feedforward compensators in MISO structure on the Allen-Bradley PLC.
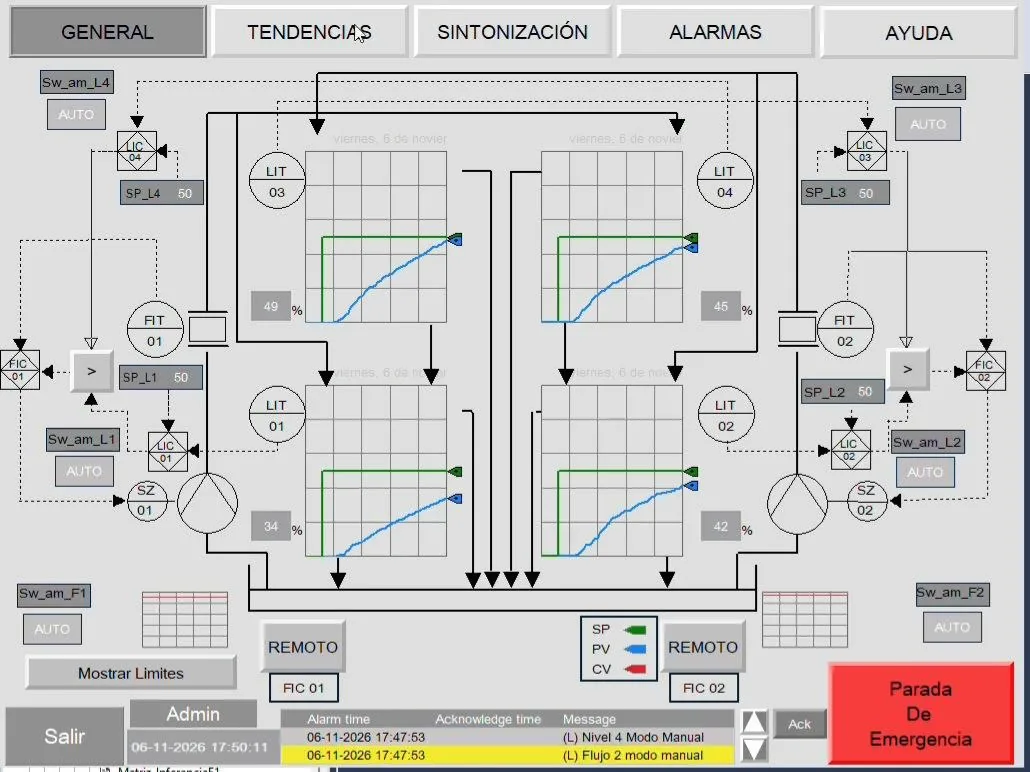
  • I collaborated on the HMI under ISA-101; the main development was handled by a classmate.
Result: The levels remained stable against a disturbance from the upper tank draining.
Demo / link: Video (YouTube)

Fig. 2.1 — HMI of the 4-tank plant with the fuzzy controller in operation; disturbance from the upper tank draining.

03
Power Electronics · Team project · Completed Dec 2025

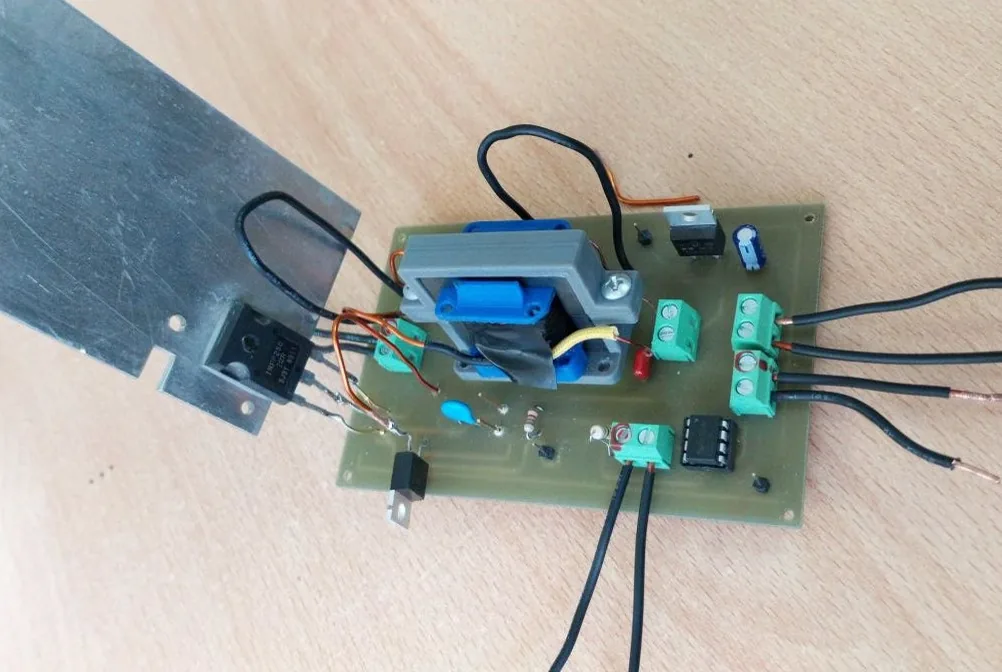
Isolated 10 W flyback converter with telemetry and HMI

Problem

Design an isolated switched-mode power supply with remote monitoring, combining power electronics, firmware and supervision.

What the team did
  • LTspice simulation at 60 kHz with RCD snubber.
  • ESP32 node measuring voltage and sending it via Wi-Fi (TCP/IP sockets).
My part
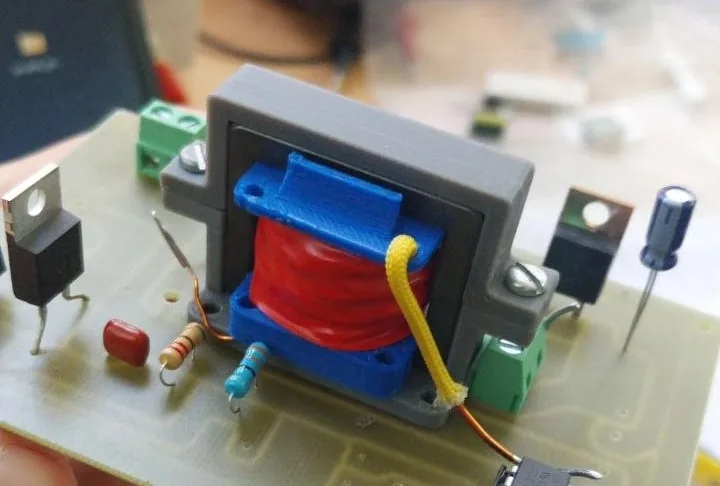
  • Calculated and hand-wound the ferrite transformer.
  • Programmed the PIC18F4550 in C to generate the PWM.
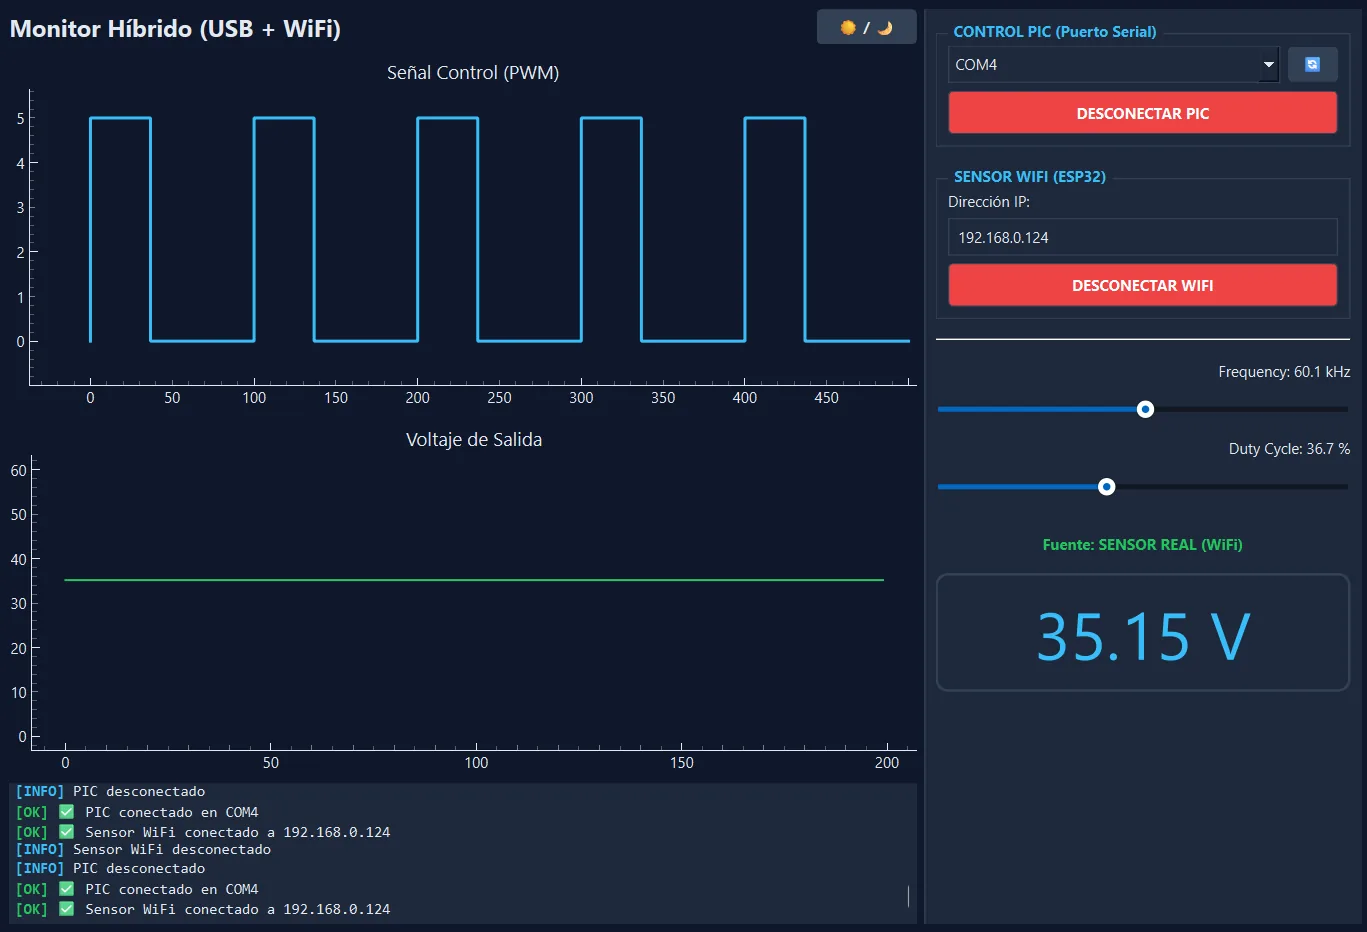
  • Developed the asynchronous HMI in Python (PySide6).
  • On the PCB, handled component selection and footprints.
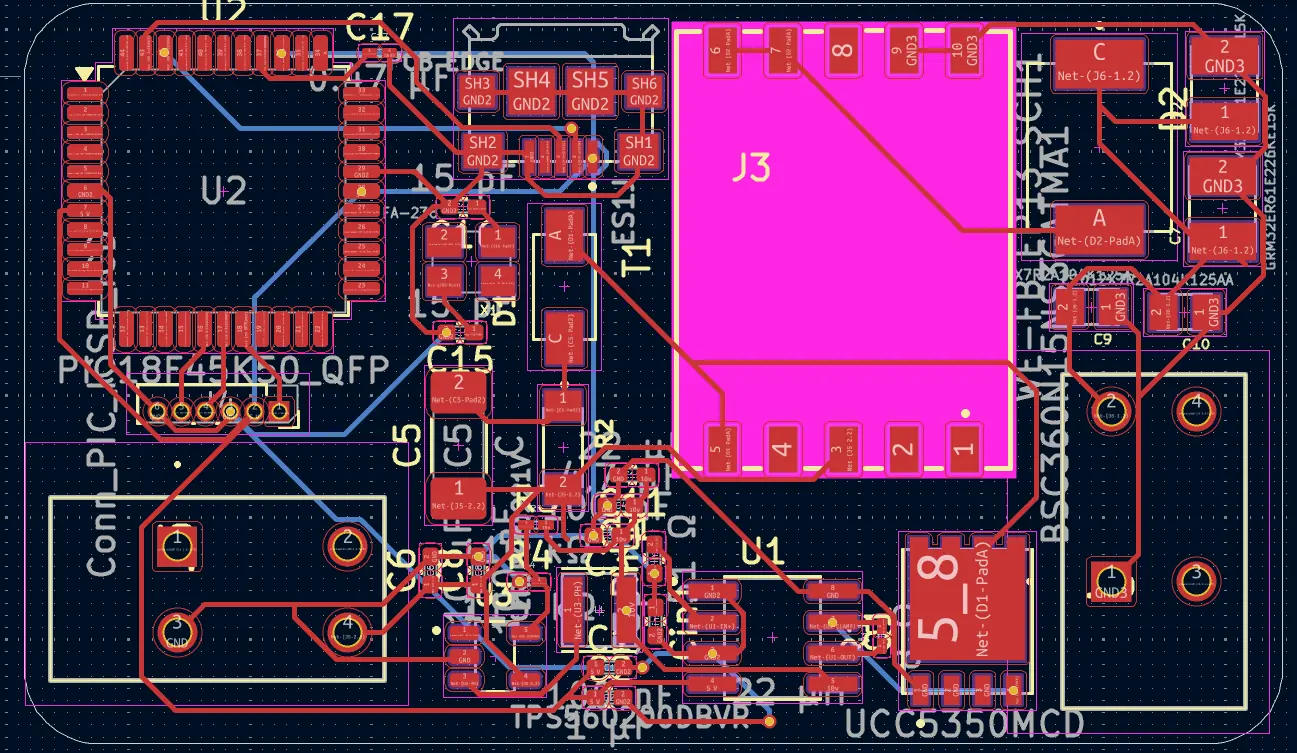
Result: The prototype measured 60 % efficiency. In the lab we identified losses from parasitic inductances and unexpected DCM operation. A redesign in KiCad with SMD and separate ground planes was designed (not manufactured).
Links and code: Report (PDF)
Flyback converter prototype
Fig. 3.1 — Prototype — assembled flyback converter under test.
Hand-wound ferrite transformer (prototype)
Fig. 3.2 — Prototype — hand-wound ferrite transformer.
Python PySide6 HMI with telemetry (prototype)
Fig. 3.3 — Prototype — Python HMI (PySide6) showing test telemetry.
KiCad PCB redesign (not manufactured)
Fig. 3.4 — Redesign — KiCad PCB (SMD, separate ground planes, not manufactured).
04
Team project · 2025-1

Batch control of a thermal plant with level, flow and temperature loops on a PLC

Problem

Implement a batch control strategy on a PLC for a plant with a tank, jacket and heat exchanger, coordinating level, flow and temperature variables through a sequence of stages and transitions.

What the team did
  • Modeled and configured the setup (jacketed tank and heat exchanger) and the level, flow and temperature loops.
  • Programmed the PID loops and commissioned the batch sequence on the PLC.
My part
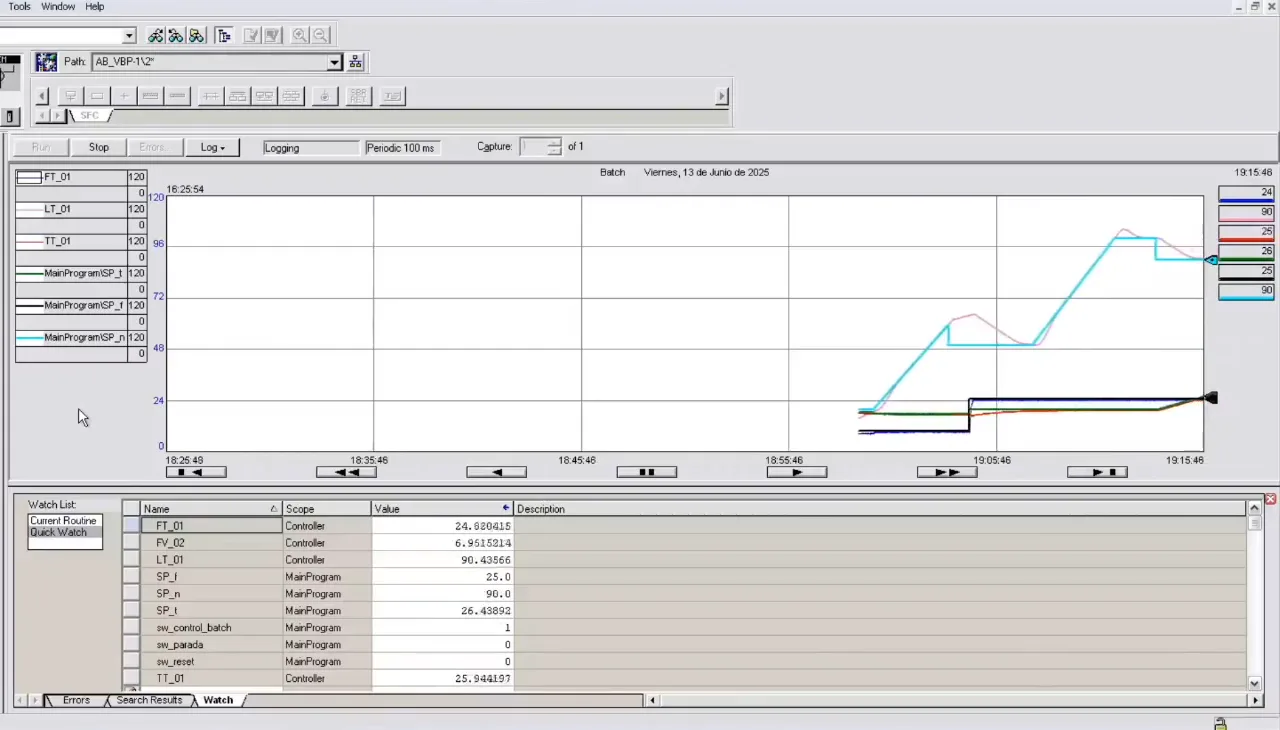
  • Implemented the SFC diagram of the batch sequence on an Allen-Bradley PLC.
  • Programmed the flow loop PID in Structured Text.
  • Tuned and applied the gain scheduler to the flow loop to handle its nonlinear behavior.
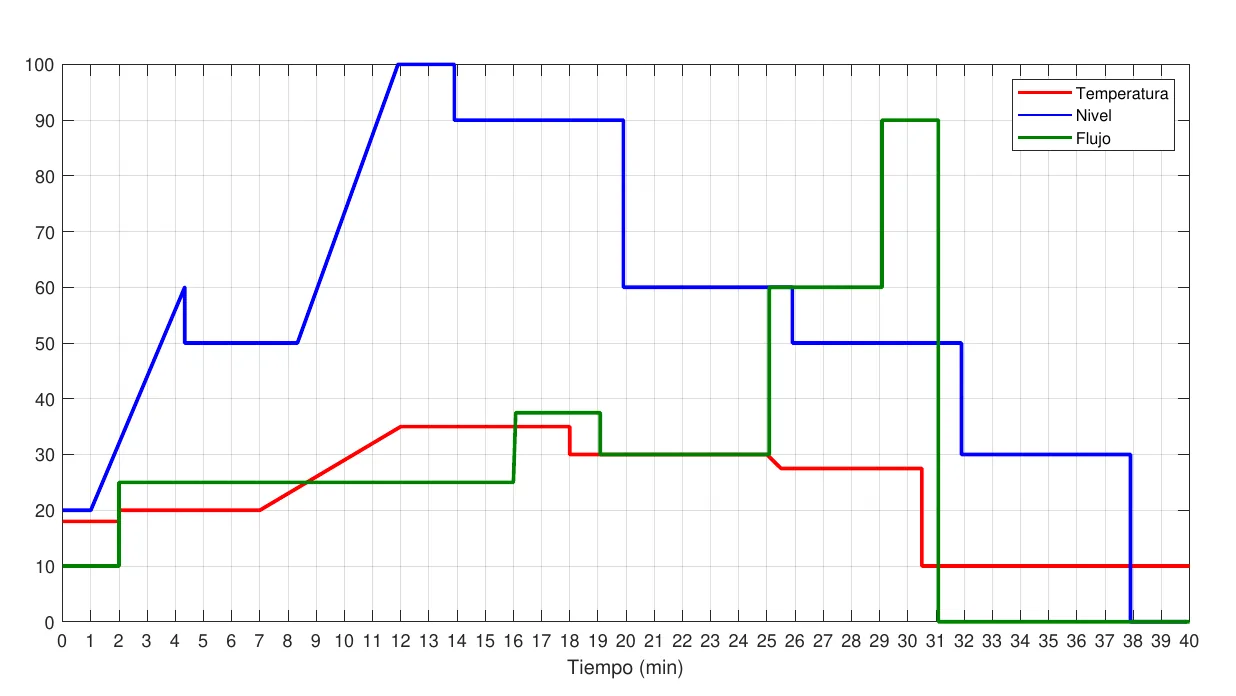
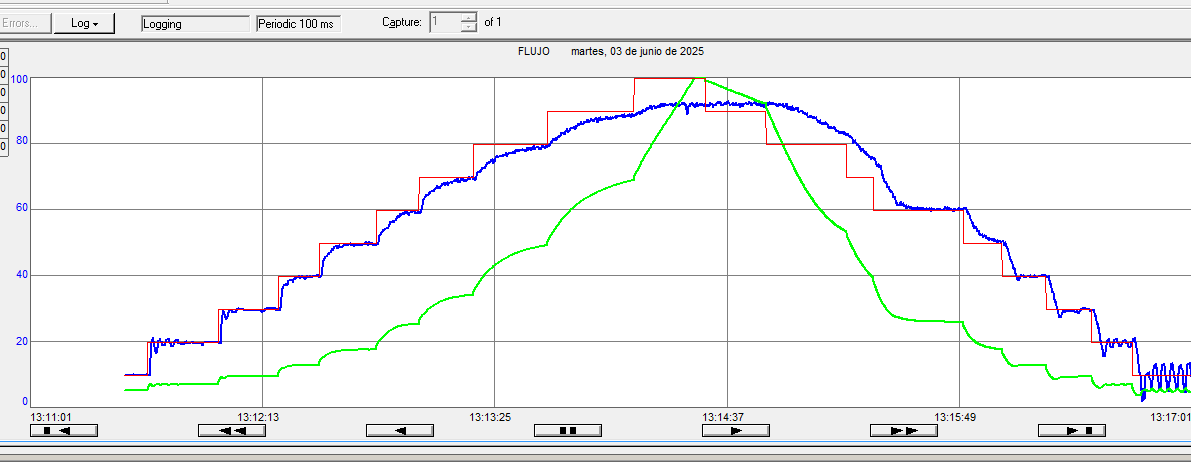
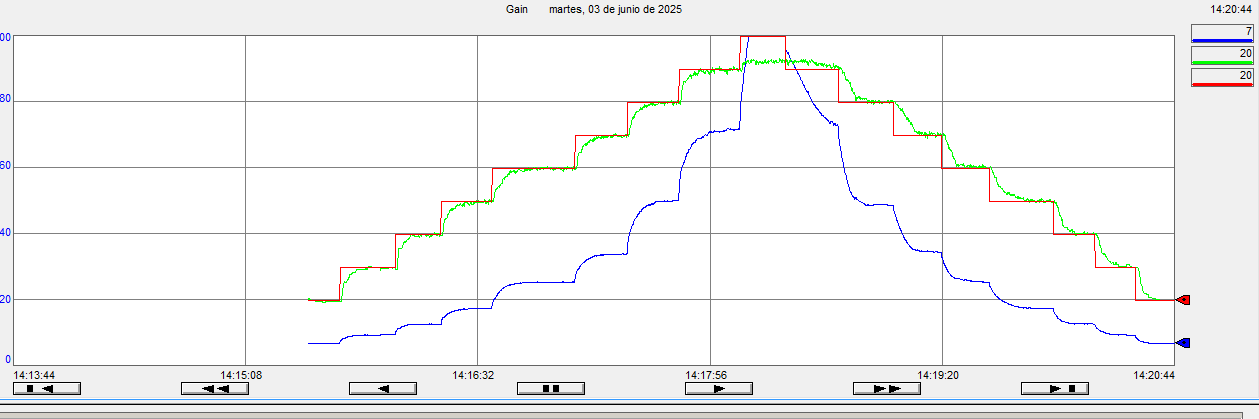
Result: With the gain scheduler, the flow loop tracked the setpoint more closely than with fixed parameters, mainly during the 90 % to 60 % step changes.
Batch recipe: programmed profile for level, flow and temperature
Fig. 4.1 — Batch recipe: programmed profile for level, flow and temperature (not measured data).
Flow test with fixed PID parameters (setpoint red, process variable blue, control signal green)
Fig. 4.2 — Flow test with fixed PID parameters. Red: setpoint, blue: process variable, green: control signal.
Flow test with gain scheduler (setpoint red, process variable green, control signal blue)
Fig. 4.3 — Flow test with gain scheduler, same setpoint profile. Red: setpoint, green: process variable, blue: control signal.
Fig. 4.4 — Batch sequence running on the PLC (RSLogix 5000 trend).

Other projects

05
Undergraduate Thesis · In progress

Study and evaluation of the degree of self-tuning and controller performance in Aspen DMC3 Calibrate

Systematic study and evaluation of the degree of self-tuning and the controller’s dynamic performance under parametric variations and degradation.

Tools

AspenTech DMC3, MATLAB/Simulink.

StatusIn progress
06
Industrial Robotics · Kinematics

6-DOF Robotic Arm

Forward/inverse kinematic modelling and control strategies for robotic manipulator joints.

Tools

MATLAB/Simulink.

StatusIn development

02. Trajectory

Jan – Mar 2026

Professional internship — CGE, San Bernardo

Power BI dashboards, project portfolio management, electrical regulation compliance.

Dec 2024 – Feb 2025

Technical assistant — Medical equipment, Concepción

Installation, instrument and sensor calibration, preventive maintenance.

03. Skills

Automation & PLC:Allen-Bradley ControlLogix, Studio 5000/RSLogix, Ladder and Structured Text (IEC 61131-3), SCADA / FactoryTalk View (ISA-101), EtherNet/IP & OPC UA.
Control & Modeling:AspenTech DMC3 (Calibrate), MATLAB / Simulink, Predictive & Fuzzy Control (Sugeno), ANFIS, Python.
Hardware, Instrumentation & Docs:KiCad, LTspice, PCB Design, PIC (C), ESP32, Python / PySide6, Laboratory instrumentation, Power BI, LaTeX.

Contact

For academic inquiries, technical collaboration, thesis work or engineering applications:

GitHub: github.com/gadivalr
LinkedIn: linkedin.com/in/levsojos
Location: Concepción, Chile
Institution: DIE UdeC